Thesis/Dissertation: Bc. Jan Mrázek: RoFI -- Distributed Metamorphic Robots
Master's thesis
RoFI -- Distributed Metamorphic Robots
Abstract
Tato práce prezentuje platormu RoFI - platformu pro distribuované metamorfické roboty. Jednotliví roboti (moduly) se mohou mechanicky spojovat a tvořit tak větší roboty (systémy), kteří mají nové schopnosti ve srovnání s jednotlivými moduly. Práce prezentuje specifikaci této platformy a navrhuje formalismus, který umožňuje formulovat tvrzení o systémech RoFI. V rámci práce jsme navrhli vhodný dokovací …more
Abstract
This work presents the RoFI platform - a platform of distributed metamorphic robots. The individual robots (modules) can mechanically connect and therefore, build larger robots (systems) with more capabilities compared to a single module. The work gives the platform specification and proposes a formalism to reason about RoFI systems. We develop a suitable docking system for coupling the robots together …more
Thesis description
12/12/2018 11:08, prof. RNDr. Jiří Barnat, Ph.D., UČO 3496
 English
Theses on a related topic
List of theses with an identical keyword.
-
Routing within RoFI Platform
Mgr. et Mgr. Vladimír Chlup -
Simulating RoFI Platform in GazeboSim
Mgr. Ondřej Svoboda -
Fault-tolerance for Metamorphic Robots
RNDr. Jan Mrázek -
Network Manager for RoFI Platform
Mgr. et Mgr. Vladimír Chlup -
Motion Planning for the RoFI Platform
Mgr. Viktória Vozárová -
Distributed-Battery Energy-Balancing Simulator
Bc. Kristián Kumor -
Reconfiguration for the RoFI Platform
Mgr. Matěj Žáček -
Graphical editor of configurations of RoFI-based robots
Bc. Jan Tojnar
Folders
Files
-
Přidání souboru
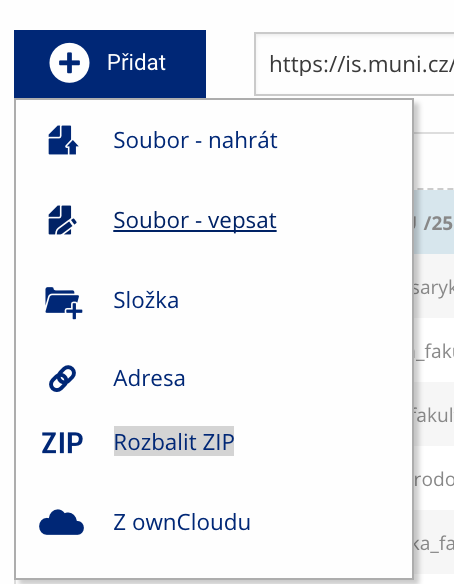 Soubor nebo složku lze nahrát pomocí tlačítka Přidat.
-
Další operace se soubory
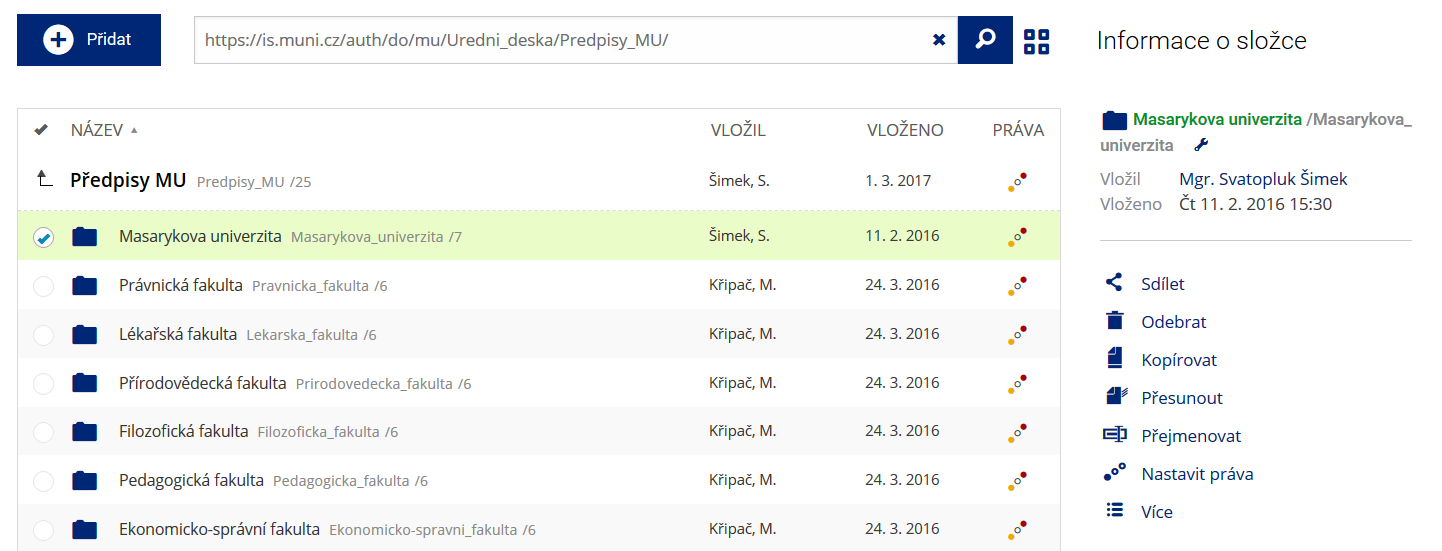 Podrobnosti lze zjistit označením příslušného řádku.
-
Pohled pro experty
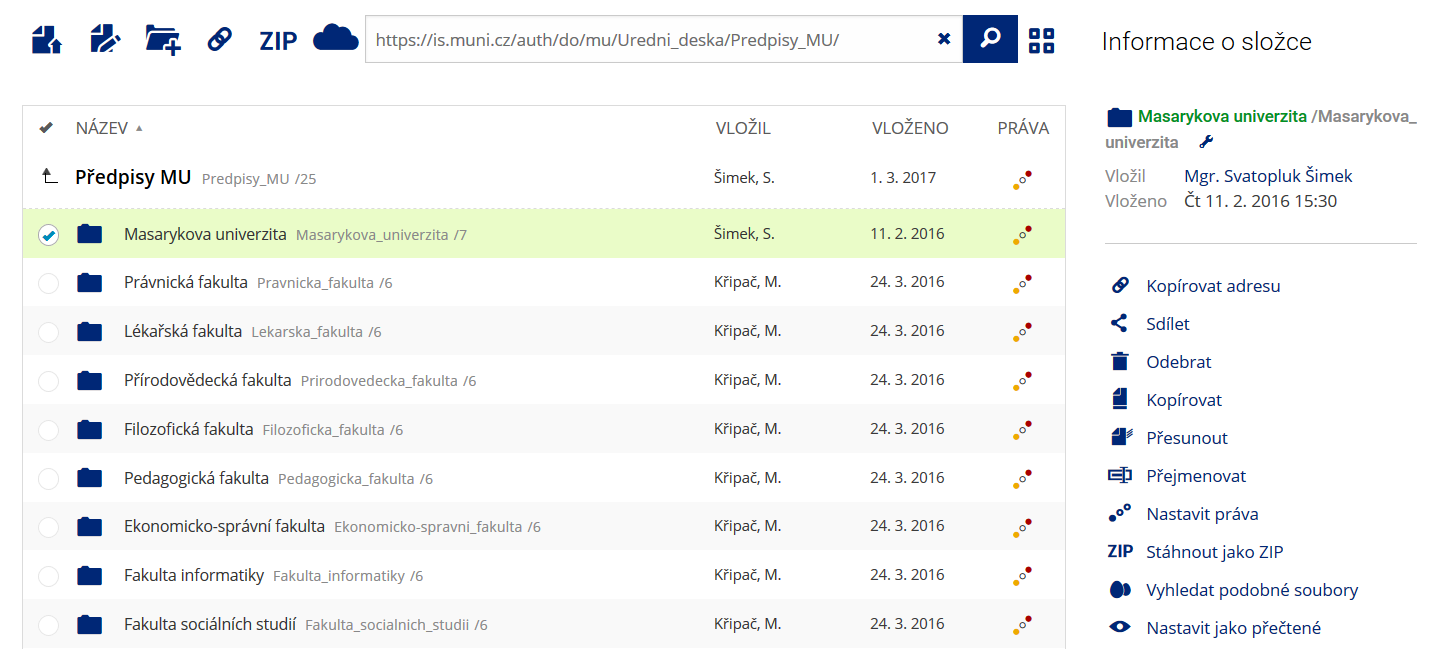 Pro častou práci je možné zvolit režim Více možností.
-
Vyhledávání souborů
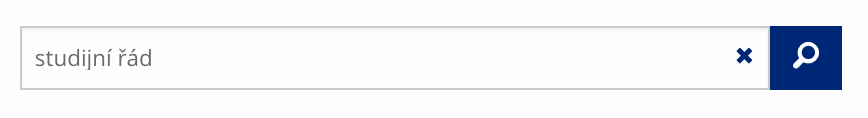 Vyhledávaný výraz můžete zadat přímo do adresního řádku.
-
Rychlý přístup k souborům
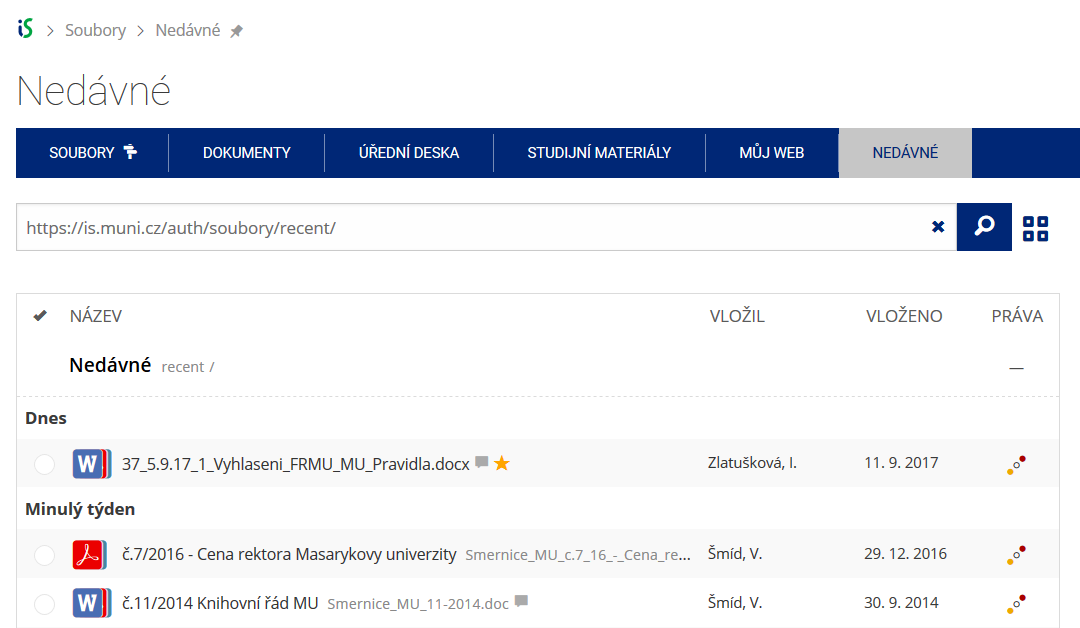 Pomocí funkce Nedávné je možné se rychle vrátit k právě prohlíženým souborům. Oblíbené soubory je také možné označit Hvězdičkou.